AM-Bench: A Modular Simulation Suite and Benchmark for Aerial Manipulation Policy Learning
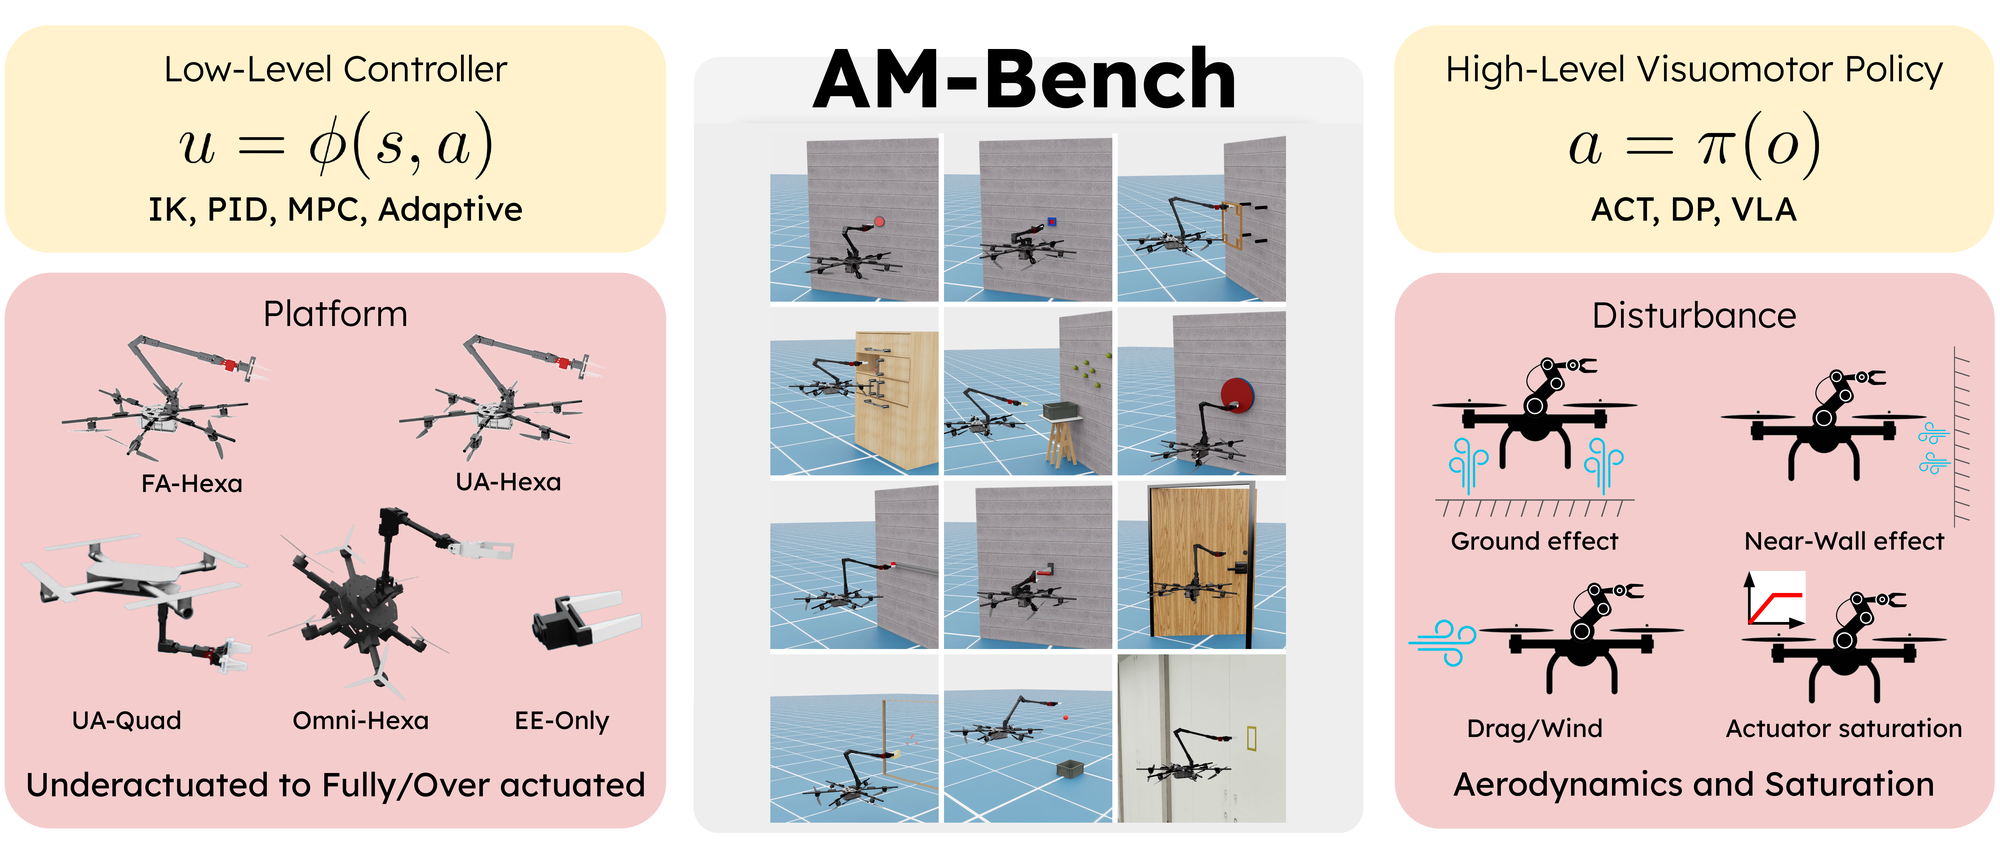
Standardized benchmarks have played a central role in advancing robot manipulation learning, yet most focus on ground-supported manipulation systems, which limits their applicability to dynamics-critical domains such as aerial manipulation (AM). AM presents distinct system-level challenges, including environmental disturbances, coupled dynamics between the manipulator and floating base, and constrained degrees of freedom. Consequently, task performance depends jointly on robot embodiment, low-level control, and high-level policy design.
We introduce AM-Bench, a modular simulation suite and benchmark for multirotor-based AM policy learning. AM-Bench includes representative embodiments spanning underactuated, fully actuated, and overactuated systems, 12 tasks across contact, transport, and constrained interaction, configurable aerodynamic disturbances and actuator saturation, standard low-level controllers, and baseline policy-learning algorithms. Unlike prior manipulation benchmarks that primarily emphasize end-to-end policy performance, AM-Bench enables system-level evaluation of how embodiment, control, disturbances, and policy choices interact.
Visit the project website for the overview video, task suite, robot embodiments, baseline results, and documentation.
Overview
Publication
BibTeX
@inproceedings{wang2026ambench,
  title={AM-Bench: A Modular Simulation Suite and Benchmark for Aerial Manipulation Policy Learning},
  author={Yutong Wang and Dongjae Lee and Xiaofeng Guo and Yuanzhu Zhan and Yufei Jiang and Bavin Saravanan and Muqing Cao and Jia Xie and Chenyang Mao and Sebastian Scherer and Junyi Geng and Guanya Shi},
  year={2026},
  booktitle={Conference on Robot Learning (CoRL)},
  pages={Accepted},
  eprint={2609.00641},
  archivePrefix={arXiv},
  primaryClass={cs.RO},
  url={https://arxiv.org/abs/2609.00641}
}